
Micro Gear Motor High Torque Low Speed Options: A Practical Selection Guide
When a machine needs High Torque at low speed, choosing a standard Dc Motor is often not enough. A motor may provide sufficient speed but lack the torque required to move a load, or it may deliver the required torque only at an inefficient operating point.
This is where a micro gear motor becomes useful.
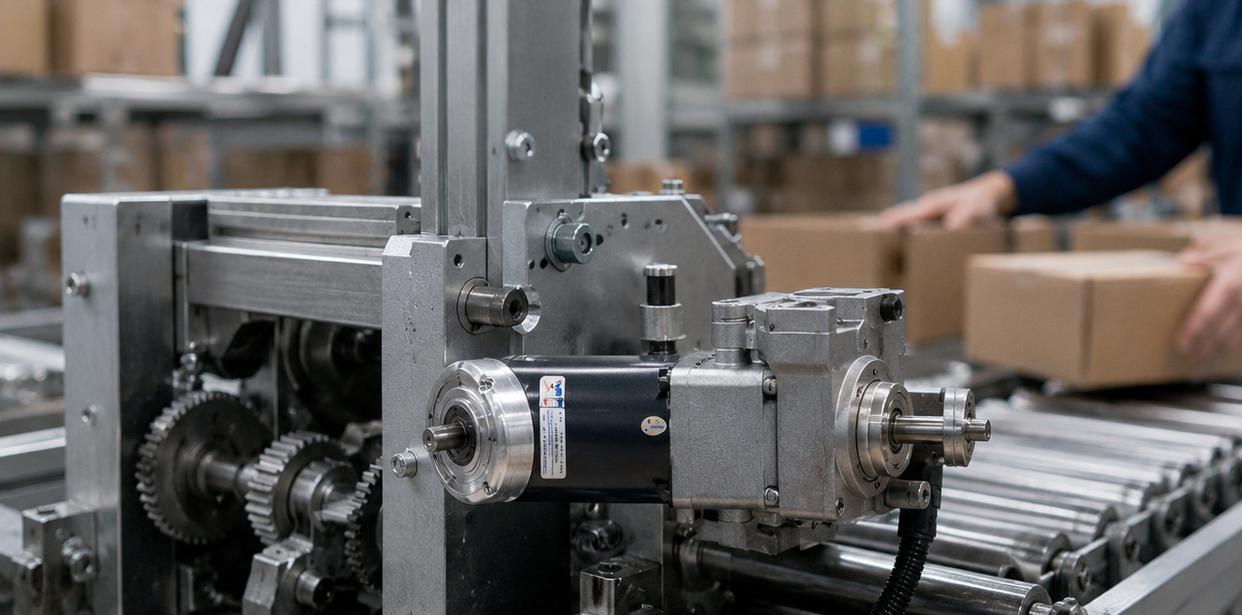
By combining a compact DC motorwith a reduction gearbox, a Gear Motor can reduce output speed while increasing available torque. This makes it suitable for compact automation equipment, robotics, medical devices, smart appliances, small actuators, dispensing systems, and many other applications where space is limited but controlled mechanical movement is required.
However, choosing the right motor is not simply a matter of selecting the highest torque specification or the lowest RPM available.
The gearbox type, reduction ratio, operating voltage, load characteristics, duty cycle, starting torque, efficiency, and available installation space all affect whether a motor will actually perform reliably in the finished product.
This guide explains the main micro gear motor high torque low speed options, how to compare them, and what specifications you should check before placing an order.
What Is a Micro Gear Motor?
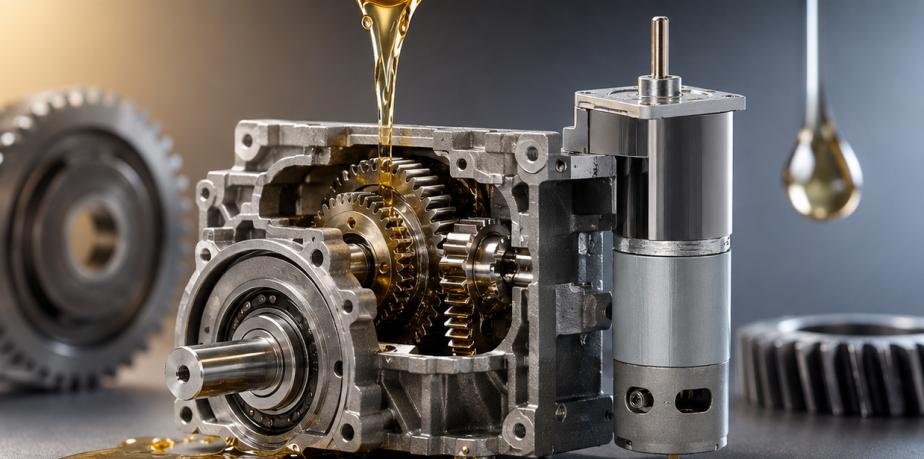
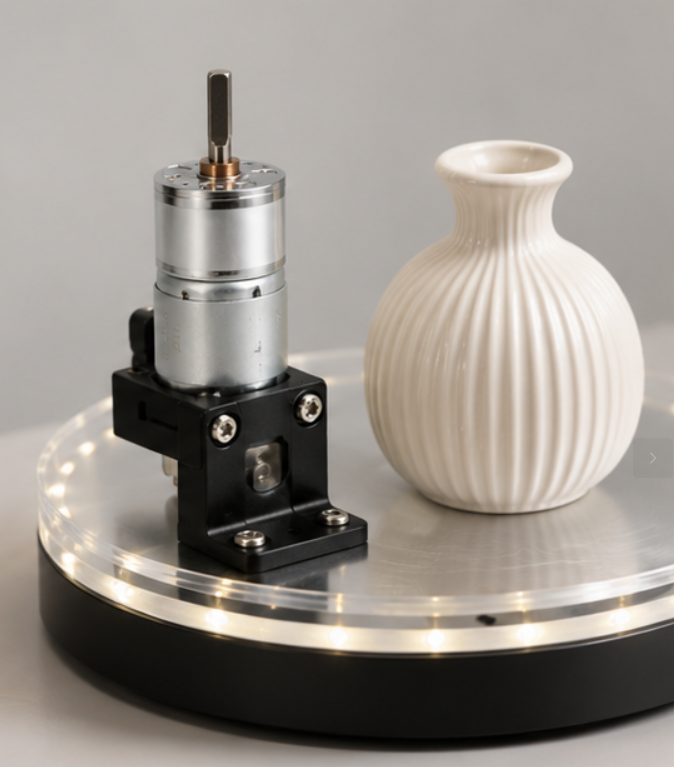
A micro gear motor is an integrated electromechanical device that combines a small electric motor with a gearbox.
The motor generates rotational power at relatively high speed. The gearbox then reduces the rotational speed and increases the torque available at the output shaft.
For example, a small DC motor may rotate at several thousand RPM without a gearbox. That speed is often too high for a mechanism that needs slow, controlled movement. Adding a reduction gearbox can bring the output speed down to a few hundred RPM, tens of RPM, or even lower, depending on the gear ratio.
The basic relationship is:
Higher reduction ratio → lower output speed → higher theoretical output torque
In practice, gearbox efficiency means the actual output torque will be lower than the theoretical value.
This trade-off is important. A motor designed for low-speed, high-torque operation should be selected based on its actual working point rather than simply its maximum or stall torque.
Why Use a High-Torque, Low-Speed Micro Motor?
Many compact machines do not need the motor shaft to rotate quickly. They need the shaft to move a mechanism with enough force and do so consistently.
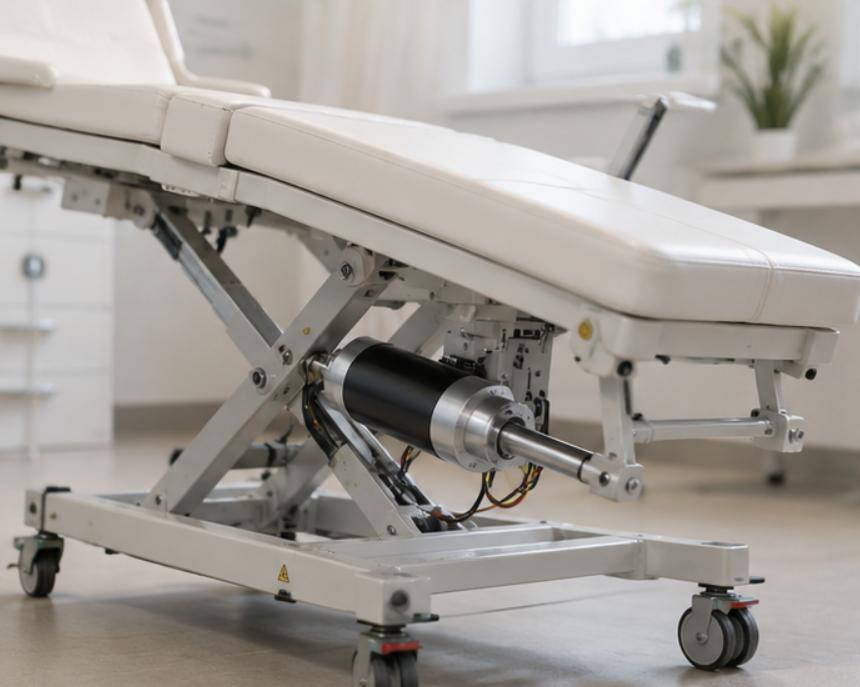
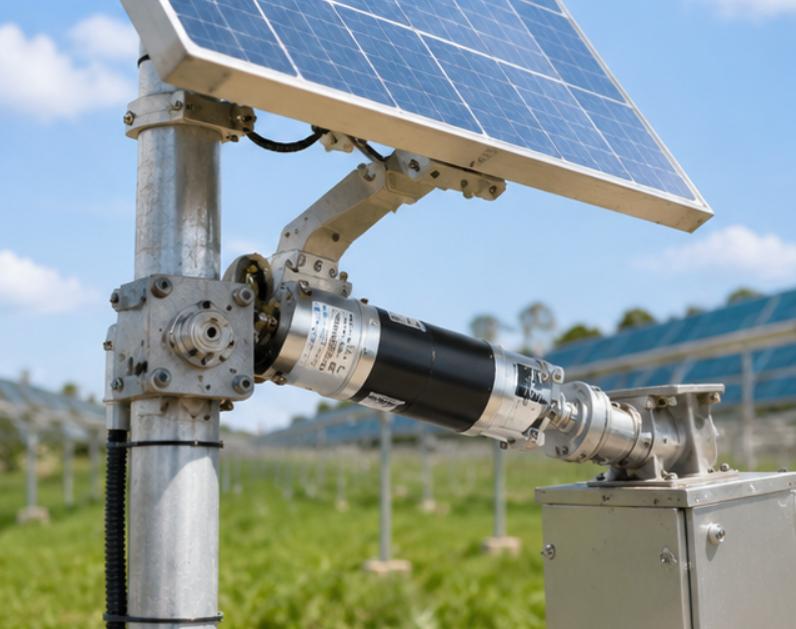
Typical examples include:
- Small robotic joints
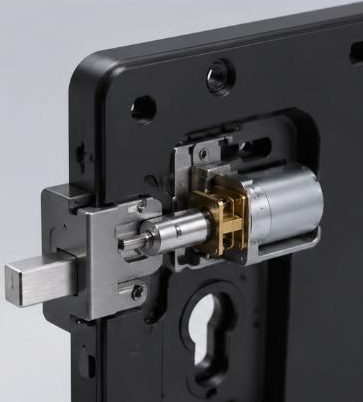
- Automatic locks and latches
- Electric valves
- Compact linear actuators
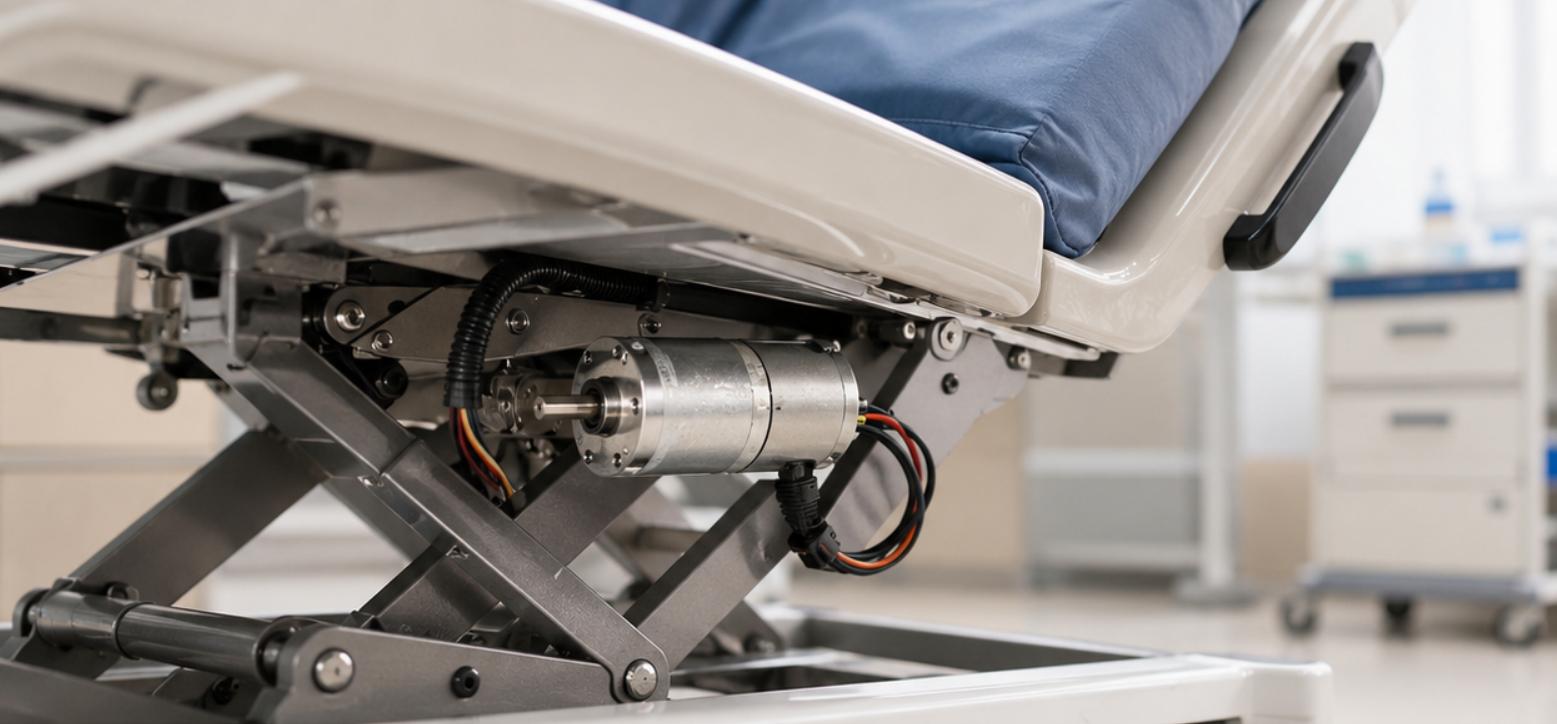
- Medical and laboratory equipment
- Miniature pumps
- Dispensing mechanisms
- Camera and optical equipment
- Smart home devices
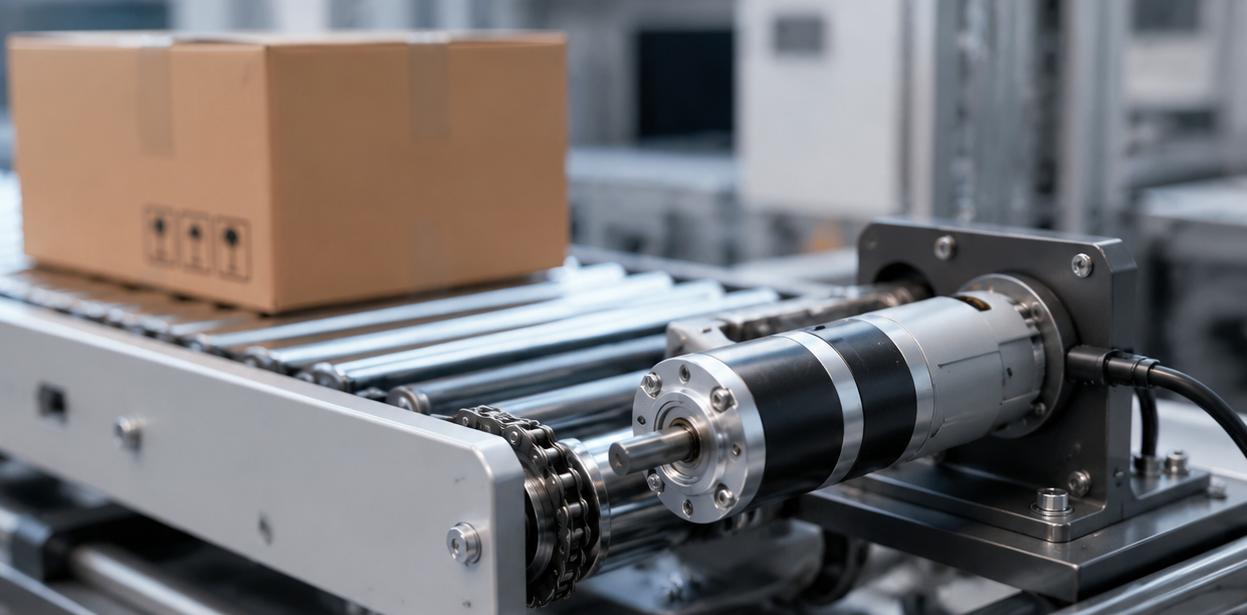
- Small conveyor mechanisms
- Automatic doors and windows
- Vending and dispensing equipment
- Office automation equipment
- Portable instruments
A low-speed gear motor can also make motion easier to control.
For example, rotating a mechanism at 3,000 RPM may be impractical if the application requires precise positioning. Reducing the speed to 30 RPM provides much more manageable output movement and allows the mechanical system to operate at a more useful speed.
The Most Important Specifications to Compare
Before choosing a motor, focus on the actual requirements of the application rather than starting with the motor model.
At minimum, you should know:
- Required output speed
- Required working torque
- Starting or peak load
- Operating voltage
- Duty cycle
- Available installation space
- Shaft configuration
- Required direction of rotation
- Expected operating lifetime
- Noise requirements
Among these specifications, output speed and working torque should normally be considered first.
What About Current Consumption?
Current is another specification that should not be overlooked.
A gear motor can draw significantly more current when starting or when the load increases. If a motor repeatedly starts under heavy load, the power supply must be capable of handling the starting current.
A system that works correctly when the motor is unloaded may fail once the actual mechanical load is introduced.
Continuous Operation vs. Intermittent Operation
A motor that works well for 10 seconds may not necessarily be suitable for continuous operation.
When a DC motor operates under load, electrical energy is converted into mechanical energy and heat. As temperature rises, winding resistance increases, which can affect current and torque.
Therefore, duty cycle is an important part of motor selection.
For demanding applications, it is better to test the actual motor under realistic load conditions rather than relying only on a catalog torque value.
How to Reduce Motor Noise and Backlash
High torque and low speed are not the only factors that matter.
For precision equipment, noise and backlash may also affect the final product.
Noise
Gear noise can be affected by:
- Gear material
- Gear tooth design
- Manufacturing accuracy
- Lubrication
- Motor speed
- Load
- Gearbox structure
If your product is used in a quiet environment, such as medical or consumer equipment, tell the motor manufacturer about the noise requirement before selecting the gearbox.
Backlash
Backlash refers to the small amount of angular movement that can occur between mating gears when the output shaft changes direction.
Some applications tolerate relatively high backlash, while precision positioning systems may require much tighter control.
If the motor repeatedly changes direction, backlash can become more noticeable.
For this reason, applications involving precise positioning should consider gearbox backlash as an important selection parameter.
Common Mistakes When Choosing a Low-Speed Gear Motor
Choosing based only on RPM
A motor may achieve the correct unloaded RPM but slow down significantly once a load is applied.
Always check performance under load.
Choosing based only on maximum torque
Maximum or stall torque is not the same as recommended continuous working torque.
Ignoring starting conditions
A mechanism may require much more torque to start than to keep moving.
Selecting the highest gear ratio
A very high reduction ratio is not automatically better. It can increase size, reduce efficiency, increase mechanical losses, or create other performance limitations.
Ignoring duty cycle
A motor suitable for intermittent operation may not be suitable for continuous running.
Choosing voltage first
The fact that a system uses 12V does not mean every 12V gear motor is suitable.
Motor speed, torque, current, gearbox ratio, and load must all be evaluated together.
Frequently Asked Questions
Q: What are the different types of DC gear motors?
A: The main types include spur gear motors, planetary gear motors, worm gear motors, and gear motors based on brushless DC motors.
Spur gear motors are commonly selected for their balance of cost, size, and efficiency. Planetary gear motors are useful when high torque density and compact dimensions are important. Worm gear motors are suitable for applications requiring high reduction ratios and specific back-driving characteristics.
The best type depends on the required torque, speed, efficiency, size, noise, backlash, and operating conditions.
Q: What is a DC gear motor used for?
A: A DC gear motor is used when an application needs controlled rotational movement with higher torque and lower speed than a standalone DC motor can conveniently provide.
Common applications include robotics, automation equipment, smart appliances, medical equipment, dispensing machines, locks, valves, small actuators, pumps, and positioning mechanisms.
The combination of a DC motor and gearbox allows designers to achieve useful output torque while keeping the overall motor package relatively compact.
Q: How does a DC gear motor work?
A: A DC motor converts electrical energy into rotational motion. The gearbox connected to the motor then reduces the rotational speed and increases the torque available at the output shaft.
The final output depends on the motor's operating point, gearbox reduction ratio, and gearbox efficiency.
For this reason, the rated gearbox output should always be evaluated together with the actual load rather than considering the gearbox ratio alone.
Q: What voltage is best for a DC gear motor?
A: There is no single best voltage for every application.
6V, 12V, and 24V DC gear motors are all commonly used, with the appropriate choice depending on the equipment's power system.
A 12V motor can be a practical choice for many compact electromechanical products, while 24V is often convenient for industrial automation systems. Battery-powered products may use lower voltages depending on their electrical architecture.
The motor voltage should match the power supply and controller, while the motor's torque, speed, and current should be checked at the same time.
Q: Can a micro gear motor run continuously?
A: Some can, but continuous operation depends on the specific motor design, load, speed, gearbox, temperature, and duty requirements.
A motor operating at high load continuously may generate considerable heat even if its rated voltage is correct.
If continuous operation is required, ask the supplier to confirm the suitable duty cycle and test the motor under the intended load.
Q: Is a higher gear ratio always better for high torque?
A: No. A higher gear ratio generally reduces output speed and increases theoretical torque, but gearbox efficiency, size, friction, noise, and other mechanical factors also need to be considered.
The ideal gear ratio is the one that provides the required speed and torque while allowing the motor and gearbox to operate within a suitable working range.
Q: How can I get more torque from a small DC gear motor?
A: The most common approach is to use an appropriate reduction ratio and select a motor capable of operating efficiently under the required load.
However, simply increasing the reduction ratio is not always the best solution.
If more torque is required, consider the complete system: motor size, winding, operating voltage, gear ratio, gearbox type, efficiency, duty cycle, and thermal conditions.
Q: What is the difference between a micro gear motor and a standard DC motor?
A: A standard DC motor usually provides relatively high rotational speed and lower torque directly from its shaft.
A micro gear motor integrates a gearbox with the motor to provide lower output speed and higher usable torque.
If your application needs fast rotation, a standard DC motor may be sufficient. If it needs slower, stronger, and more controlled movement, a gear motor is often more appropriate.
Final Selection Checklist
Before ordering a high-torque, low-speed gear motor, make sure you can answer these questions:
- What output RPM do I need?
- What torque is required during normal operation?
- What is the peak or starting load?
- What voltage is available?
- How much current can the power supply provide?
- How frequently will the motor operate?
- Will it run continuously or intermittently?
- What gearbox type is appropriate?
- How much space is available?
- Is backlash important?
- Is noise important?
- What shaft and mounting dimensions are required?
- What service life is expected?
- Has the motor been tested under the real application load?
Getting these details right before ordering samples can save considerable time during product development.
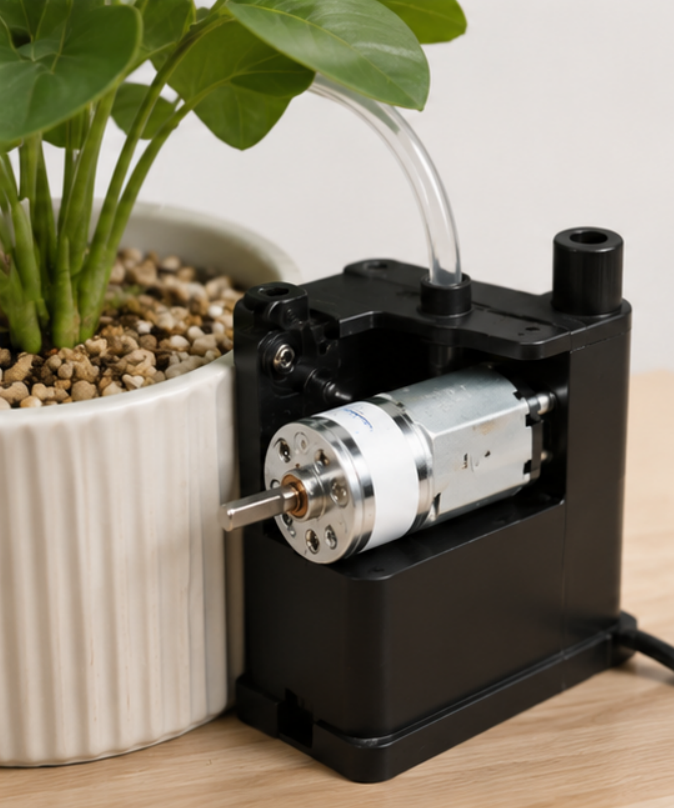
Choosing the Right Micro Gear Motor for Your Application
There is no single micro gear motor that is ideal for every high-torque, low-speed application.
The right solution depends on the relationship between output speed, working torque, gear ratio, voltage, current, duty cycle, gearbox design, physical dimensions, and operating environment.
For general applications, a compact spur gear motor can provide an effective balance between performance and cost. When higher torque density is required, a planetary design may be more suitable. For very high reduction ratios and specific holding or back-driving requirements, a worm gear motor can be considered.
Most importantly, select the motor based on the actual working conditions, not just the numbers printed on a product specification sheet.
If you are comparing different high torque low speed motor options and are unsure which specification is suitable, providing the required voltage, output RPM, working torque, load, duty cycle, and available dimensions to the motor manufacturer is usually the fastest way to identify a suitable model.
A good motor selection is not simply about finding the motor with the highest torque. It is about finding the motor that can deliver the right torque, at the right speed, under the right load, for the required operating life.
That is what turns a motor specification into a reliable solution.